Publications
2026
CASTER: Formalizing zero-shot manipulation from synthetic videos as constrained optimizationYinlong Dai, Homanga Bharadhwaj, Dylan P. LoseyRead Paper Project Website |
 |
Assisting for open-ended tasks: Goal-oriented shared autonomy as a particle filterMengxue Fu, Ethan Xu, Sam Iyer-Singh, Yinlong Dai, Michael Hagenow, Dylan P. LoseyRead Paper |
 |
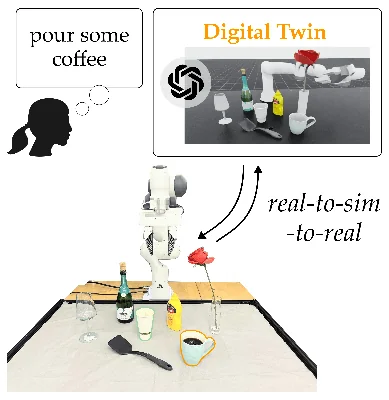
GraspTwin: Zero-shot task-oriented grasp optimization via a digital twinDaniel J. Evans, Yinlong Dai, Simon Stepputtis, Dylan P. LoseyRead Paper |
 |
Show and tell: Unifying physical demonstrations and language corrections for neuro-symbolic robotsBenjamin A. Christie, Siddarth Jain, Dylan P. LoseyRead Paper |
 |
PAIR: Proprioception-aligned image-ray representations for viewpoint-robust manipulationSung-Wook Lee, Xuhui Kang, Dylan P. Losey, Yen-Ling KuoRead Paper |
 |
In view or out of view? A vision-aware filter that infers and reacts to the human's field of viewMengxue Fu, Ya-Chuan Hsu, Yinlong Dai, Erdem Bıyık, Dylan P. LoseyRead Paper |
 |
Belief-aware influence and trust (BAIT): Shaping human belief during repeated human-robot interactionYe-Ji Mun, Mahsa Golchoubian, Shahabedin Sagheb, Yan Bai, Tianhao Ji, Andrea Bajcsy, Dylan P. Losey, Katherine Driggs-CampbellRead Paper |
 |
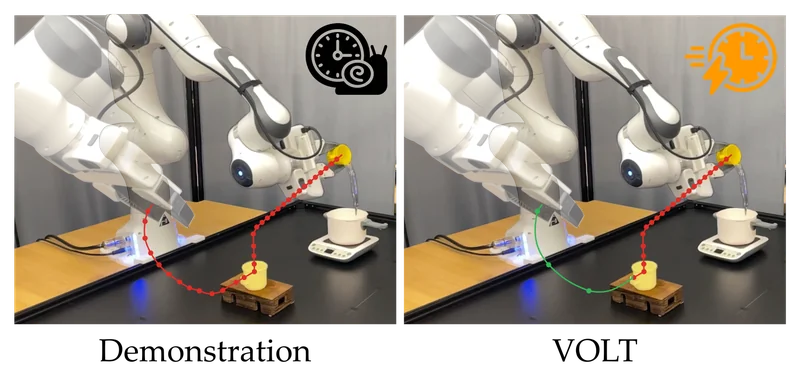
VOLT: Vision and language trajectory segmentation for faster-than-demonstration policiesRobert Ramirez Sanchez, Daniel J. Evans, Dylan P. Losey, Siddarth JainRead Paper |
 |
Safe interactions via Monte Carlo linear-quadratic gamesBenjamin A. Christie, Dylan P. LoseyRead Paper |
 |
TransMASK: Masked state representation through learned transformationSagar Parekh, Preston Culbertson, Dylan P. LoseyRead Paper Project Website |
 |
From local corrections to generalized skills: Improving neuro-symbolic policies with MEMOBenjamin A. Christie, Yinlong Dai, Mohammad Bararjanianbahnamiri, Simon Stepputtis, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper Project Website |
 |
A pivot-based kirigami utensil for hand-held and robot-assisted feedingKeone Leao, Grace Brotherson, Iain Mischel, Sagar Parekh, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Curvature-aware calibration of tactile sensors for accurate force estimation on non-planar surfacesLuoyan Zhong, Heather Jin Hee Kim, Dylan P. Losey, Cara M. NunezHaptics Symposium Read Paper |
 |
Fine-tuning robot policies while maintaining user privacyBenjamin A. Christie, Sagar Parekh, Dylan P. LoseyRead Paper |
 |
Combining performance and passivity in linear control of series elastic actuatorsShaunak A. Mehta, Dylan P. LoseyRead Paper |
 |
Teleoperator-aware and safety-critical adaptive nonlinear MPC for shared autonomy in obstacle avoidance of legged robotsRuturaj Sambhus, Muneeb Ahmad, Basit Muhammad Imran, Sujith Vijayan, Dylan P. Losey, Kaveh Akbari HamedRead Paper |
 |
Language movement primitives: Grounding language models in robot motionYinlong Dai, Benjamin A. Christie, Daniel J. Evans, Dylan P. Losey, and Simon StepputtisRead Paper Project Website |
 |
Shared control/autonomy in human-robot interaction: Current trends and the role of generative AIMichael Hagenow, Mario Selvaggio, Xuehui Yu, Yanwei Wang, Yiannis Demiris, Andreea Bobu, Yilun Du, Harold Soh, Dylan P. Losey, Julie ShahRead Paper |
 |
2025
Prepare before you act: Learning from humans to rearrange initial statesYinlong Dai, Andre Keyser, Dylan P. LoseyIEEE International Conference on Robotics and Automation Read Paper |
 |
Towards robots that learn from humansDylan P. LoseyRead Paper |
 |
Towards balanced behavior cloning from imbalanced datasetsSagar Parekh, Heramb Nemlekar, Dylan P. LoseyAutonomous Robots Read Paper Project Website |
 |
Safe and transparent robots for human-in-the-loop meat processingSagar Parekh, Casey Grothoff, Ryan Wright, Robin White, Dylan P. LoseyRead Paper |
 |
A modular haptic display with reconfigurable signals for personalized information transferAntonio Alvarez Valdivia, Benjamin A. Christie, Dylan P. Losey, Laura H. BlumenscheinIEEE Transactions on Haptics Read Paper |
 |
L2D2: Robot learning from 2D drawingsShaunak A. Mehta, Heramb Nemlekar, Hari Sumant, Dylan P. LoseyAutonomous Robots Read Paper Project Website |
 |
Counterfactual behavior cloning: Offline imitation learning from imperfect human demonstrationsShahabedin Sagheb, Dylan P. LoseyACM Transactions on Human-Robot Interaction Read Paper |
 |
CIVIL: Causal and intuitive visual imitation learningYinlong Dai, Robert Ramirez Sanchez, Ryan Jeronimus, Shahabedin Sagheb, Cara M. Nunez, Heramb Nemlekar, Dylan P. LoseyAutonomous Robots Read Paper |
 |
A unified framework for robots that influence humans over long-term interactionShahabedin Sagheb, Sagar Parekh, Ravi Pandya, Ye-Ji Mun, Katherine Driggs-Campbell, Andrea Bajcsy, Dylan P. LoseyRead Paper |
 |
Kiri-Spoon: A kirigami utensil for robot-assisted feedingMaya Keely, Brandon Franco, Casey Grothoff, Rajat Kumar Jenamani, Tapomayukh Bhattacharjee, Dylan P. Losey, Heramb NemlekarThe International Journal of Robotics Research Read Paper |
 |
RECON: Reducing causal confusion with human-placed markersRobert Ramirez Sanchez, Heramb Nemlekar, Shahabedin Sagheb, Cara M. Nunez, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Using high-level patterns to estimate how humans predict a robot will behaveSagar Parekh, Lauren Bramblett, Nicola Bezzo, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Personalizing interfaces to humans with user-friendly priorsBenjamin A. Christie, Heramb Nemlekar, Dylan P. LoseyIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
2024
PECAN: Personalizing robot behaviors through a learned canonical spaceHeramb Nemlekar, Robert Ramirez Sanchez, Dylan P. LoseyACM Transactions on Human-Robot Interaction Read Paper |
 |
Should collaborative robots be transparent?Shahabedin Sagheb, Soham Gandhi, Dylan P. LoseyInternational Journal of Social Robotics Read Paper |
 |
Stable-BC: Controlling covariate shift with stable behavior cloningShaunak A. Mehta, Yusuf Umut Ciftci, Balamurugan Ramachandran, Somil Bansal, Dylan P. LoseyIEEE Robotics and Automation Letters Read Paper Project Website |
 |
VIEW: Visual imitation learning with waypointsAnanth Jonnavittula, Sagar Parekh, Dylan P. LoseyAutonomous Robots Read Paper Project Website |
 |
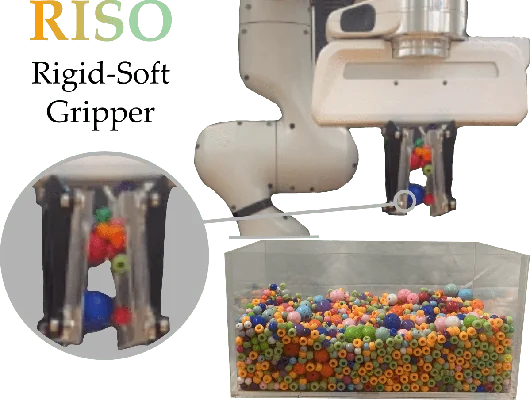
Combining and decoupling rigid and soft grippers to enhance robotic manipulationMaya Keely, Yeunhee Kim, Shaunak A. Mehta, Joshua Hoegerman, Robert Ramirez Sanchez, Emily Paul, Camryn Mills, Dylan P. Losey, Michael D. BartlettSoft Robotics Read Paper |
 |
Kiri-Spoon: A soft shape-changing utensil for robot-assisted feedingMaya N. Keely, Heramb Nemlekar, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Waypoint-based reinforcement learning for robot manipulation tasksShaunak A. Mehta, Soheil Habibian, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper Project Website |
 |
Aligning learning with communication in shared autonomyJoshua Hoegerman, Shahabedin Sagheb, Benjamin A. Christie, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
A survey of communicating robot learning during human-robot interactionSoheil Habibian, Antonio Alvarez Valdivia, Laura H. Blumenschein, Dylan P. LoseyThe International Journal of Robotics Research Read Paper |
 |
LIMIT: Learning interfaces to maximize information transferBenjamin A. Christie, Dylan P. LoseyACM Transactions on Human-Robot Interaction Read Paper |
 |
SARI: Shared autonomy across repeated interactionAnanth Jonnavittula, Shaunak A. Mehta, Dylan P. LoseyACM Transactions on Human-Robot Interaction Read Paper |
 |
2023
Safely and autonomously cutting meat with a collaborative robot armRyan Wright, Sagar Parekh, Robin White, Dylan P. LoseyScientific Reports Read Paper |
 |
StROL: Stabilized and robust online learning from humansShaunak A. Mehta, Forrest Meng, Andrea Bajcsy, Dylan P. LoseyIEEE Robotics and Automation Letters Read Paper |
 |
Reward learning with intractable normalizing functionsJoshua Hoegerman, Dylan P. LoseyIEEE Robotics and Automation Letters Read Paper |
 |
Coordinated multi-robot shared autonomy based on scheduling and demonstrationsMichael Hagenow, Emmanuel Senft, Nitzan Orr, Robert Radwin, Michael Gleicher, Bilge Mutlu, Dylan P. Losey, Michael ZinnIEEE Robotics and Automation Letters Read Paper |
 |
Unified learning from demonstrations, corrections, and preferences during physical human-robot interactionShaunak A. Mehta, Dylan P. LoseyACM Transactions on Human-Robot Interaction Read Paper |
 |
Learning latent representations to co-adapt to humansSagar Parekh, Dylan P. LoseyAutonomous Robots Read Paper |
 |
RISO: Combining rigid grippers with soft switchable adhesivesShaunak A. Mehta, Yeunhee Kim, Joshua Hoegerman, Michael D. Bartlett, Dylan P. LoseyIEEE International Conference on Soft Robotics (RoboSoft) Read Paper |
 |
Towards robots that influence humans over long-term interactionShahabedin Sagheb, Ye-Ji Mun, Neema Ahmadian, Benjamin A. Christie, Andrea Bajcsy, Katherine Driggs-Campbell, Dylan P. LoseyIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
Wrapping haptic displays around robot arms to communicate learningAntonio Alvarez Valdivia, Soheil Habibian, Carly A. Mendenhall, Francesco Fuentes, Ritish Shailly, Dylan P. Losey, Laura H. BlumenscheinIEEE Transactions on Haptics Read Paper |
 |
2022
Encouraging human interaction with robot teams: Legible and fair subtask allocationsSoheil Habibian, Dylan P. LoseyIEEE Robotics and Automation Letters Read Paper |
 |
RILI: Robustly influencing latent intentSagar Parekh, Soheil Habibian, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Wrapped haptic display for communicating physical robot learningAntonio Alvarez Valdivia, Ritish Shailly, Naman Seth, Francesco Fuentes, Dylan P. Losey, Laura H. BlumenscheinIEEE International Conference on Soft Robotics (RoboSoft) Read Paper |
 |
Learning latent actions without human demonstrationsShaunak A. Mehta, Sagar Parekh, Dylan P. LoseyIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
Communicating robot conventions through shared autonomyAnanth Jonnavittula, Dylan P. LoseyIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
Assisting operators of articulated machinery with optimal planning and goal inferenceEhsan Yousefi, Dylan P. Losey, Inna SharfIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
Here’s what I’ve learned: Asking questions that reveal reward learningSoheil Habibian, Ananth Jonnavittula, Dylan P. LoseyACM Transactions on Human-Robot Interaction Read Paper |
 |
2021
Communicating inferred goals with passive augmented reality and active haptic feedbackJames F. Mullen Jr, Josh Mosier, Sounak Chakrabarti, Anqi Chen, Tyler White, Dylan P. LoseyIEEE Robotics and Automation Letters Read Paper |
 |
Learning to share autonomy across repeated interactionAnanth Jonnavittula, Dylan P. LoseyIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Physical interaction as communication: Learning robot objectives online from human correctionsDylan P. Losey, Andrea Bajcsy, Marcia K. O'Malley, Anca D. DraganThe International Journal of Robotics Research Read Paper |
 |
Learning reward functions from diverse sources of human feedback: Optimally integrating demonstrations and preferencesErdem Bıyık, Dylan P. Losey, Malayandi Palan, Nicholas C. Landolfi, Gleb Shevchuk, Dorsa SadighThe International Journal of Robotics Research Read Paper |
 |
Learning latent actions to control assistive robotsDylan P. Losey, Hong Jun Jeon, Mengxi Li, Krishnan Srinivasan, Ajay Mandlekar, Animesh Garg, Jeannette Bohg, Dorsa SadighAutonomous Robots Read Paper |
 |
Learning visually guided latent actions for assistive teleoperationSiddharth Karamcheti, Albert J. Zhai, Dylan P. Losey, Dorsa SadighLearning for Dynamics & Control (L4DC) Read Paper |
 |
I know what you meant: Learning human objectives by (under)estimating their choice setAnanth Jonnavittula, Dylan P. LoseyIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
Learning human objectives from sequences of physical correctionsMengxi Li, Alper Canberk, Dylan P. Losey, Dorsa SadighIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
2020
Learning latent representations to influence multi-agent interactionAnnie Xie, Dylan P. Losey, Ryan Tolsma, Chelsea Finn, Dorsa SadighConference on Robot Learning (CoRL) Read Paper |
 |
Learning user-preferred mappings for intuitive robot controlMengxi Li, Dylan P. Losey, Jeannette Bohg, Dorsa SadighIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Shared autonomy with learned latent actionsHong Jun Jeon, Dylan P. Losey, Dorsa SadighRobotics: Science and Systems (RSS) Read Paper |
 |
When humans aren’t optimal: Robots that collaborate with risk-aware humansMinae Kwon, Erdem Bıyık, Aditi Talati, Karan Bhasin, Dylan P. Losey, Dorsa SadighACM/IEEE International Conference on Human-Robot Interaction (HRI) Read Paper |
 |
Controlling assistive robots with learned latent actionsDylan P. Losey, Krishnan Srinivasan, Ajay Mandlekar, Animesh Garg, Dorsa SadighIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
2019
Learning the correct robot trajectory in real-time from physical human interactionsDylan P. Losey, Marcia K. O'MalleyACM Transactions on Human-Robot Interaction Read Paper |
 |
Learning from my partner’s actions: Roles in decentralized robot teamsDylan P. Losey*, Mengxi Li*, Jeannette Bohg, Dorsa SadighConference on Robot Learning (CoRL) Read Paper |
 |
Asking easy questions: A user-friendly approach to active reward learningErdem Bıyık, Malayandi Palan, Nicholas C. Landolfi, Dylan P. Losey, Dorsa SadighConference on Robot Learning (CoRL) Read Paper |
 |
Robots that take advantage of human trustDylan P. Losey, Dorsa SadighIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) Read Paper |
 |
Improving short-term retention after robotic training by leveraging fixed-gain controllersDylan P. Losey, Laura Blumenschein, Janelle Clark, Marcia K. O'MalleyJournal of Rehabilitation and Assistive Technologies Engineering Read Paper |
 |
Enabling robots to infer how end-users teach and learn through human-robot interactionDylan P. Losey, Marcia K. O'MalleyIEEE Robotics and Automation Letters Read Paper |
 |
2018
Trajectory deformations from physical human-robot interactionDylan P. Losey, Marcia K. O'MalleyIEEE Transactions on Robotics Read Paper |
 |
A review of intent detection, arbitration, and communication aspects of shared control for physical human-robot interactionDylan P. Losey, Craig G. McDonald, Edoardo Battaglia, Marcia K. O’MalleyApplied Mechanics Reviews Read Paper |
 |
Including uncertainty when learning from human correctionsDylan P. Losey, Marcia K. O'MalleyConference on Robot Learning (CoRL) Read Paper |
 |
Learning from physical human corrections, one feature at a timeAndrea Bajcsy, Dylan P. Losey, Marcia K. O’Malley, Anca D. DraganACM/IEEE International Conference on Human-Robot Interaction (HRI) Read Paper |
 |
2017
Learning robot objectives from physical human interactionAndrea Bajcsy*, Dylan P. Losey*, Marcia K. O’Malley, Anca D. DraganConference on Robot Learning (CoRL) Read Paper |
 |
Effects of discretization on the K-width of series elastic actuatorsDylan P. Losey, Marcia K. O'MalleyIEEE International Conference on Robotics and Automation (ICRA) Read Paper |
 |
2016
A time domain approach to control of series elastic actuators: Adaptive torque and passivity-based impedance controlDylan P. Losey, Andrew Erwin, Craig G. McDonald, Fabrizio Sergi, Marcia K. O’MalleyIEEE/ASME Transactions on Mechatronics Read Paper |
 |
Minimal assist-as-needed controller for upper limb robotic rehabilitationAli Utku Pehlivan, Dylan P. Losey, Marcia K. O'MalleyIEEE Transactions on Robotics Read Paper |
 |